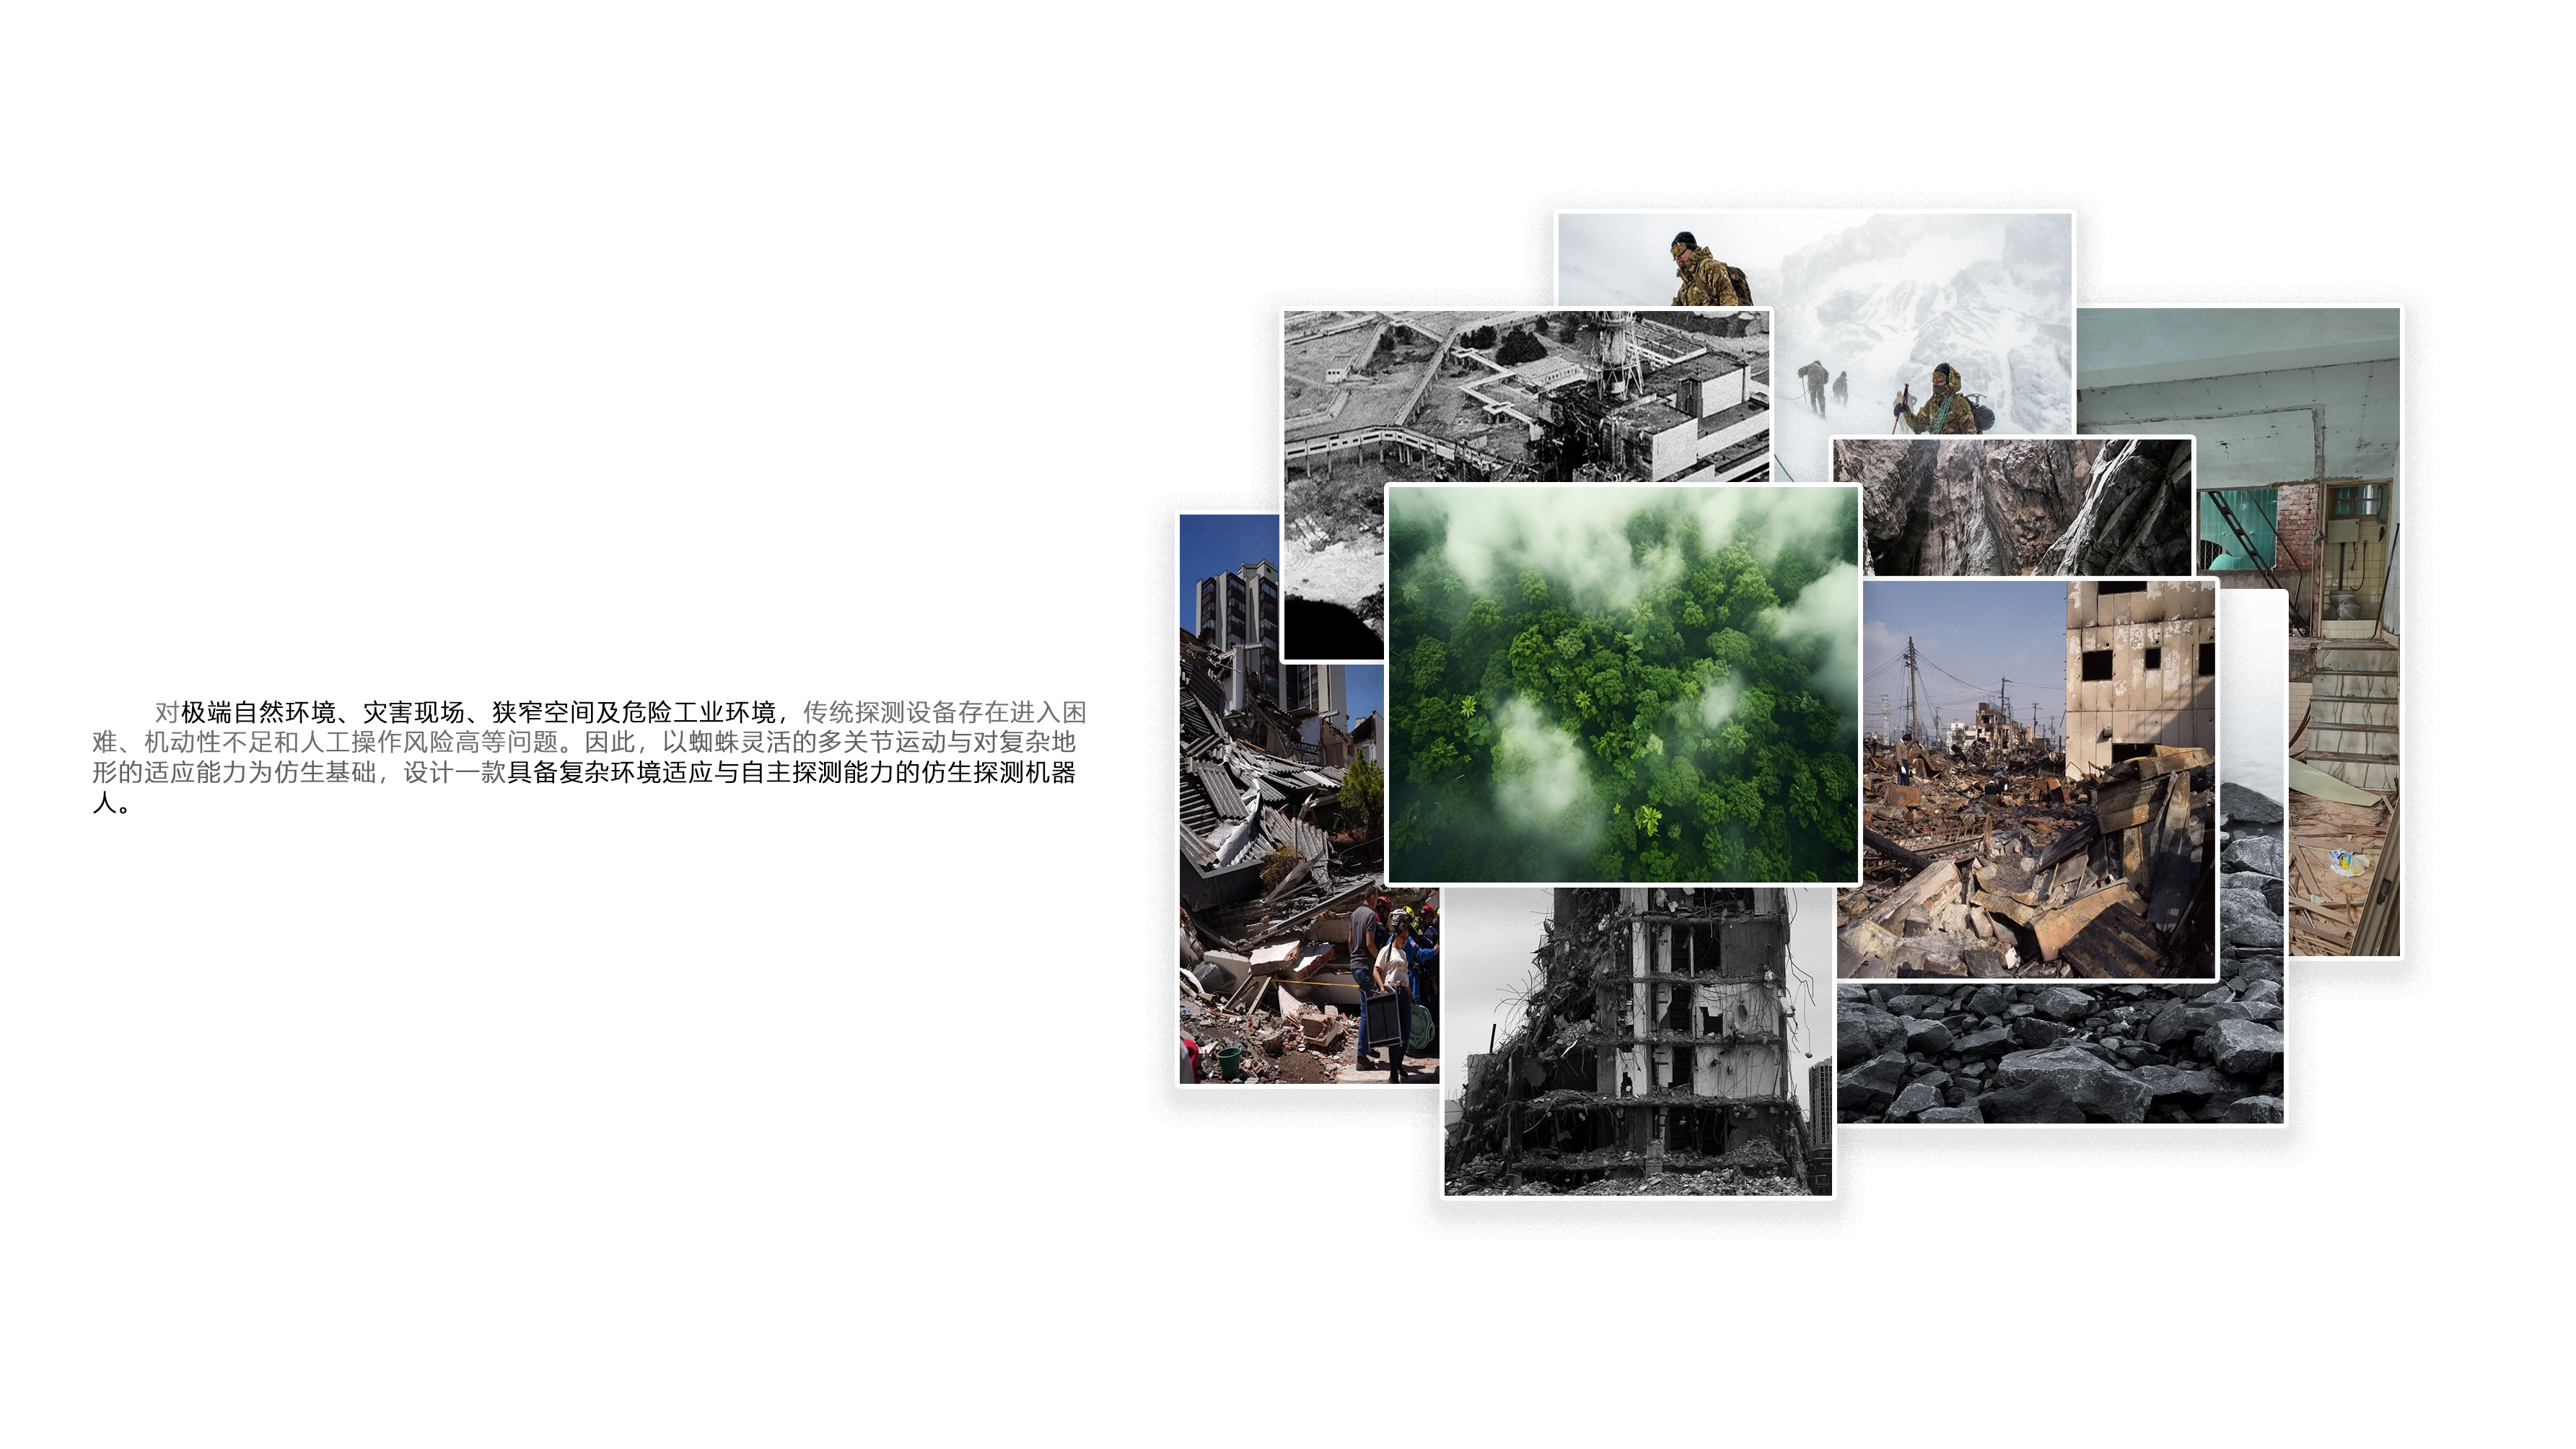
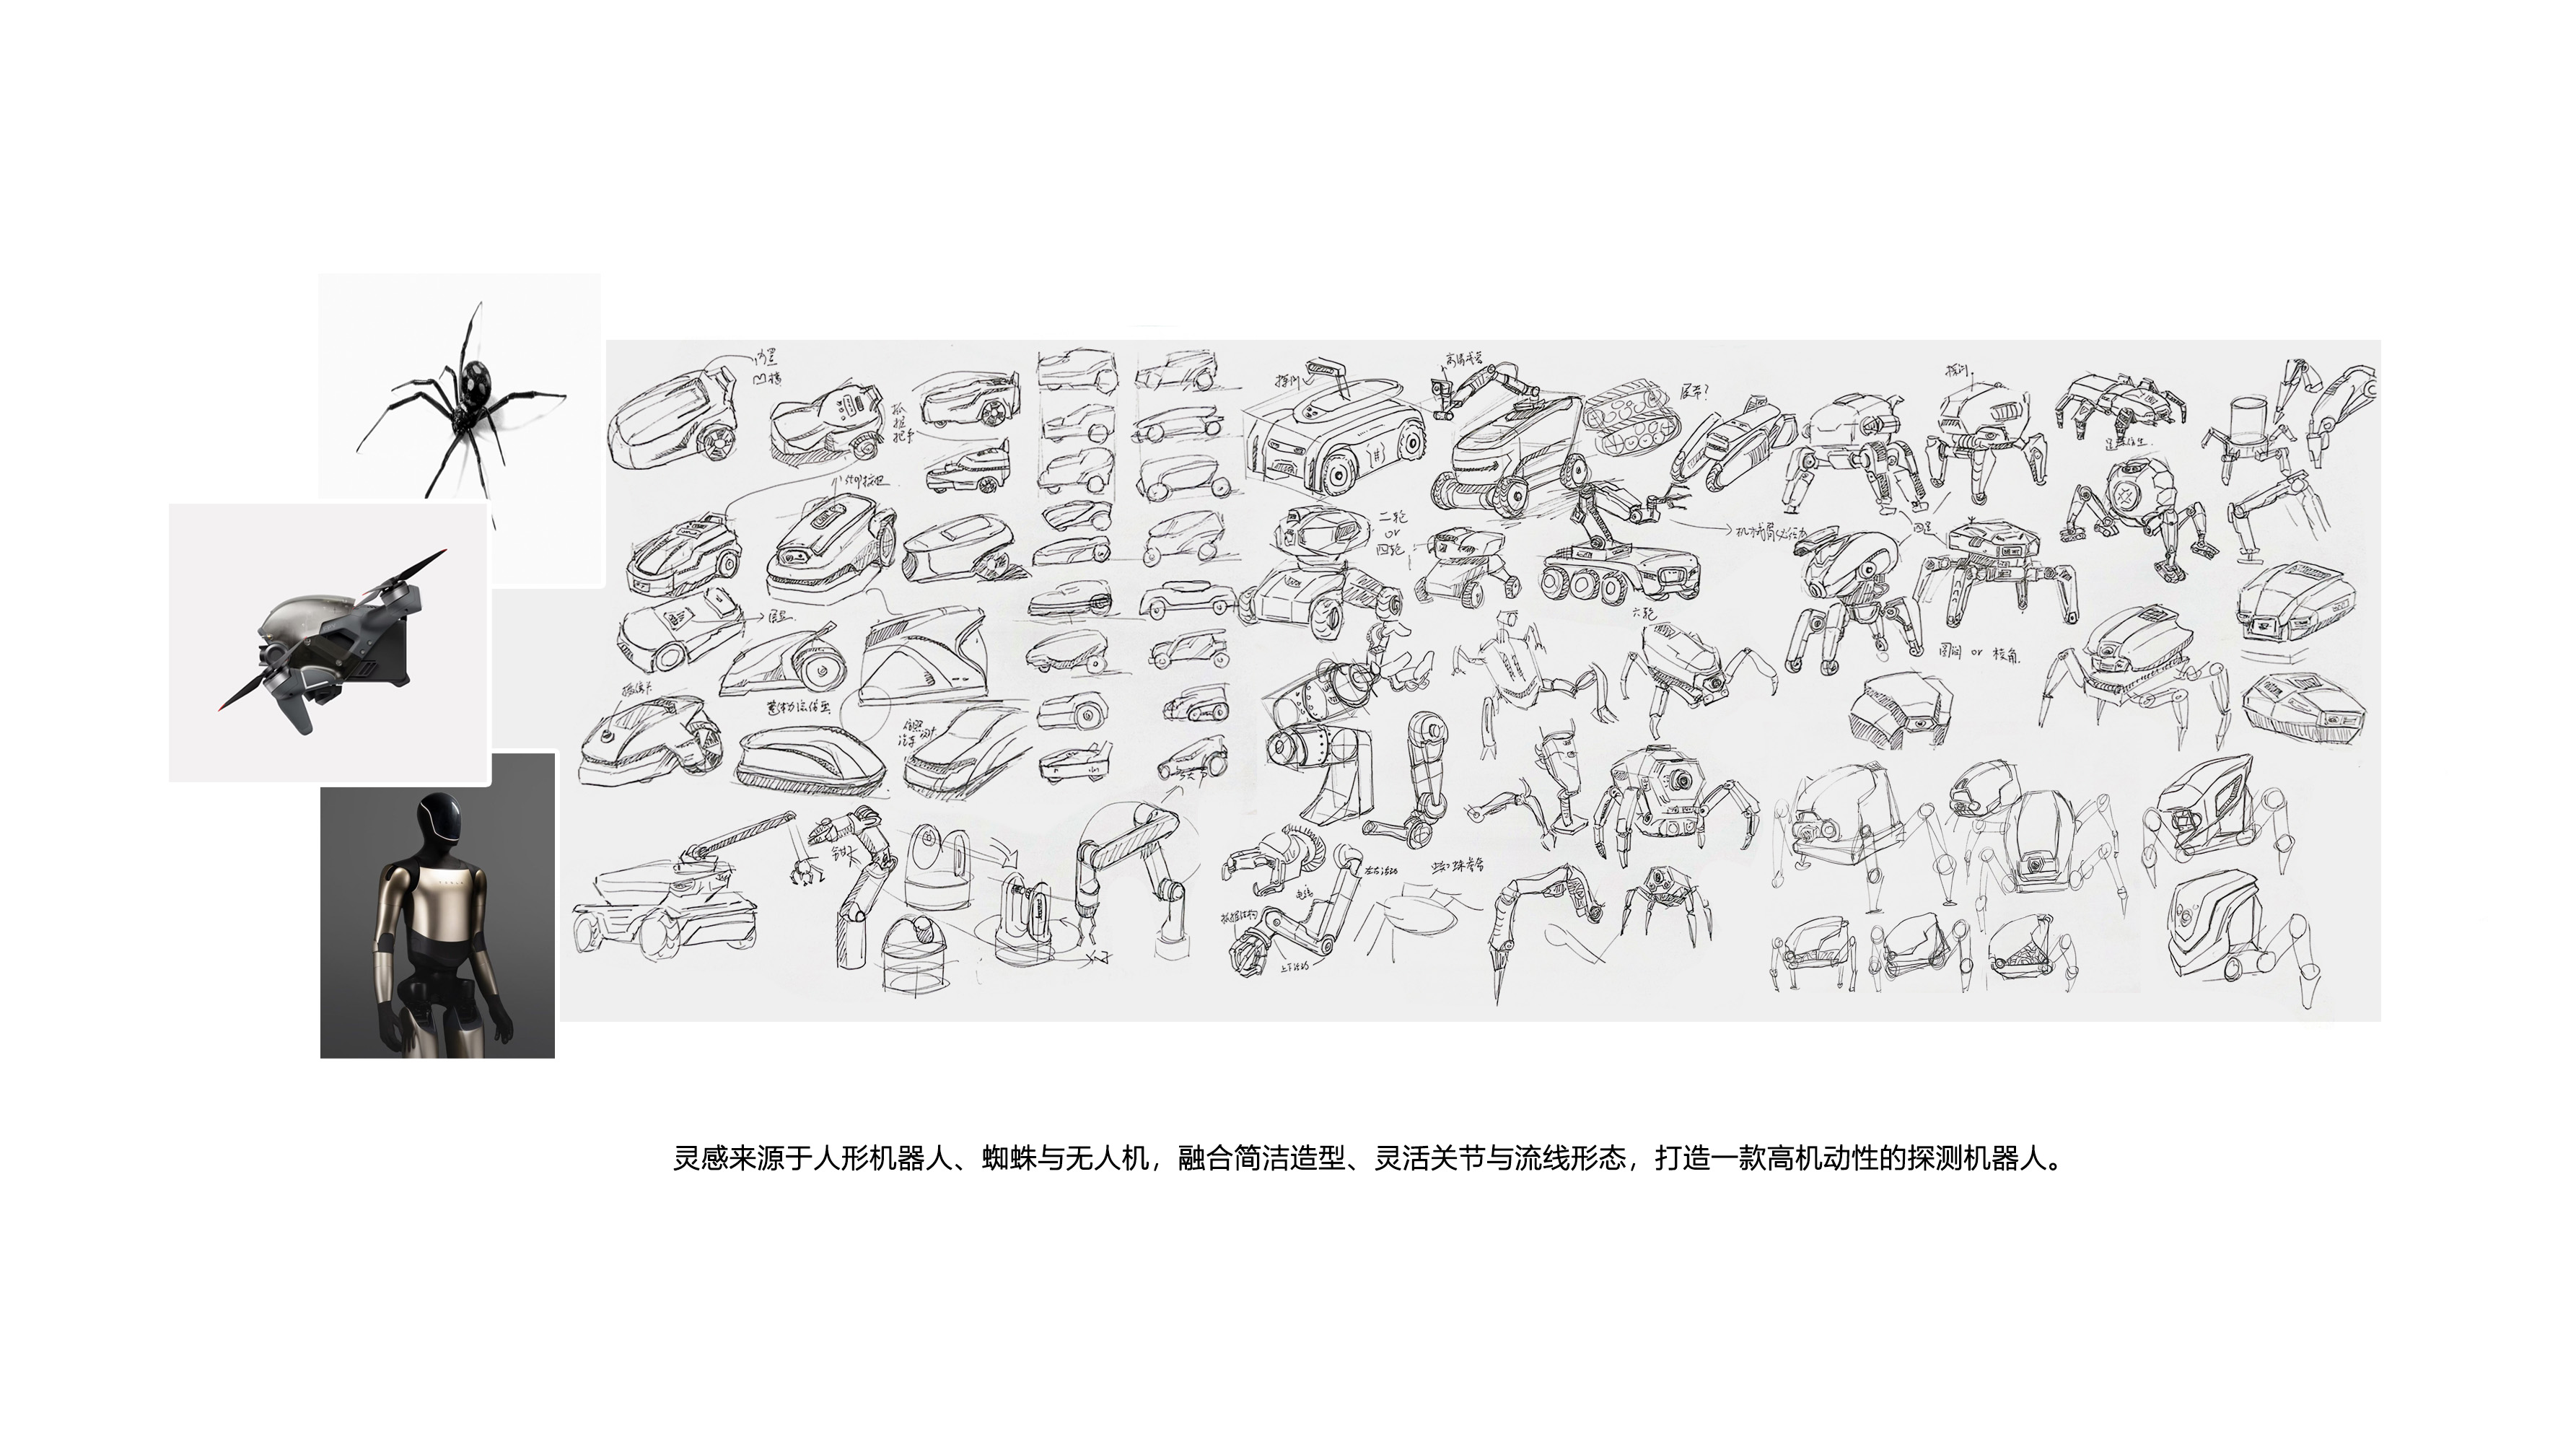
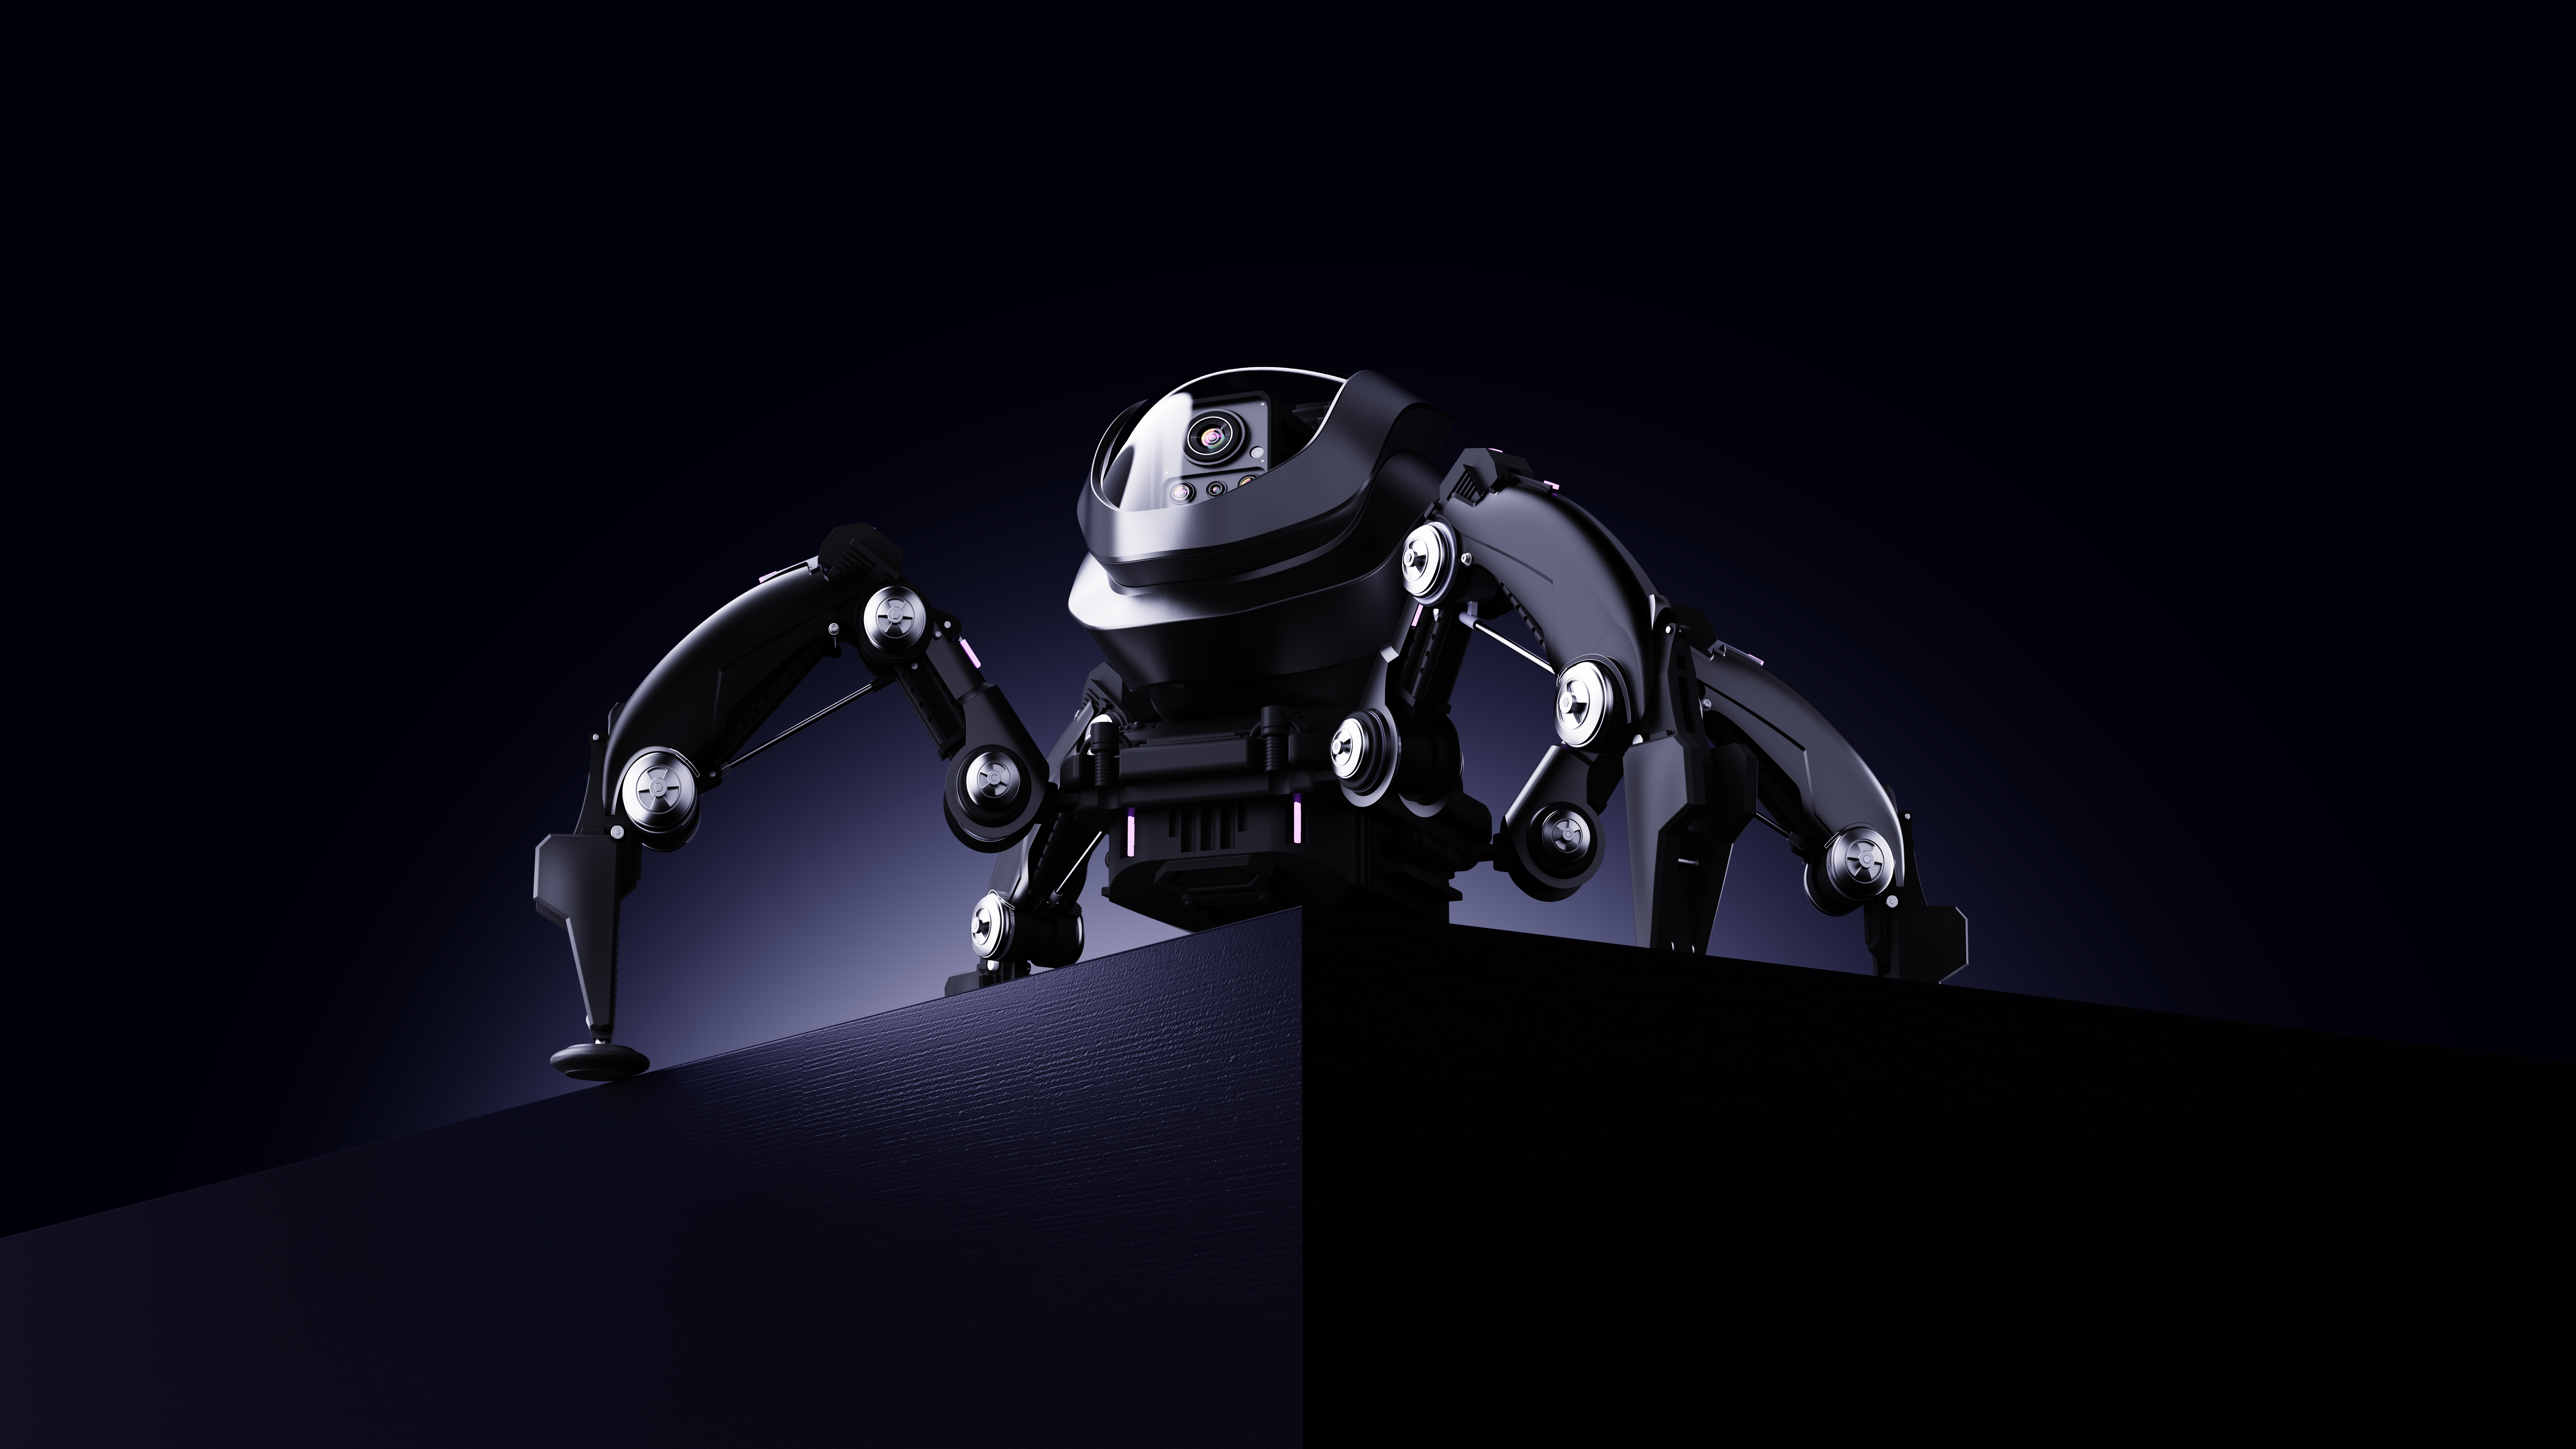
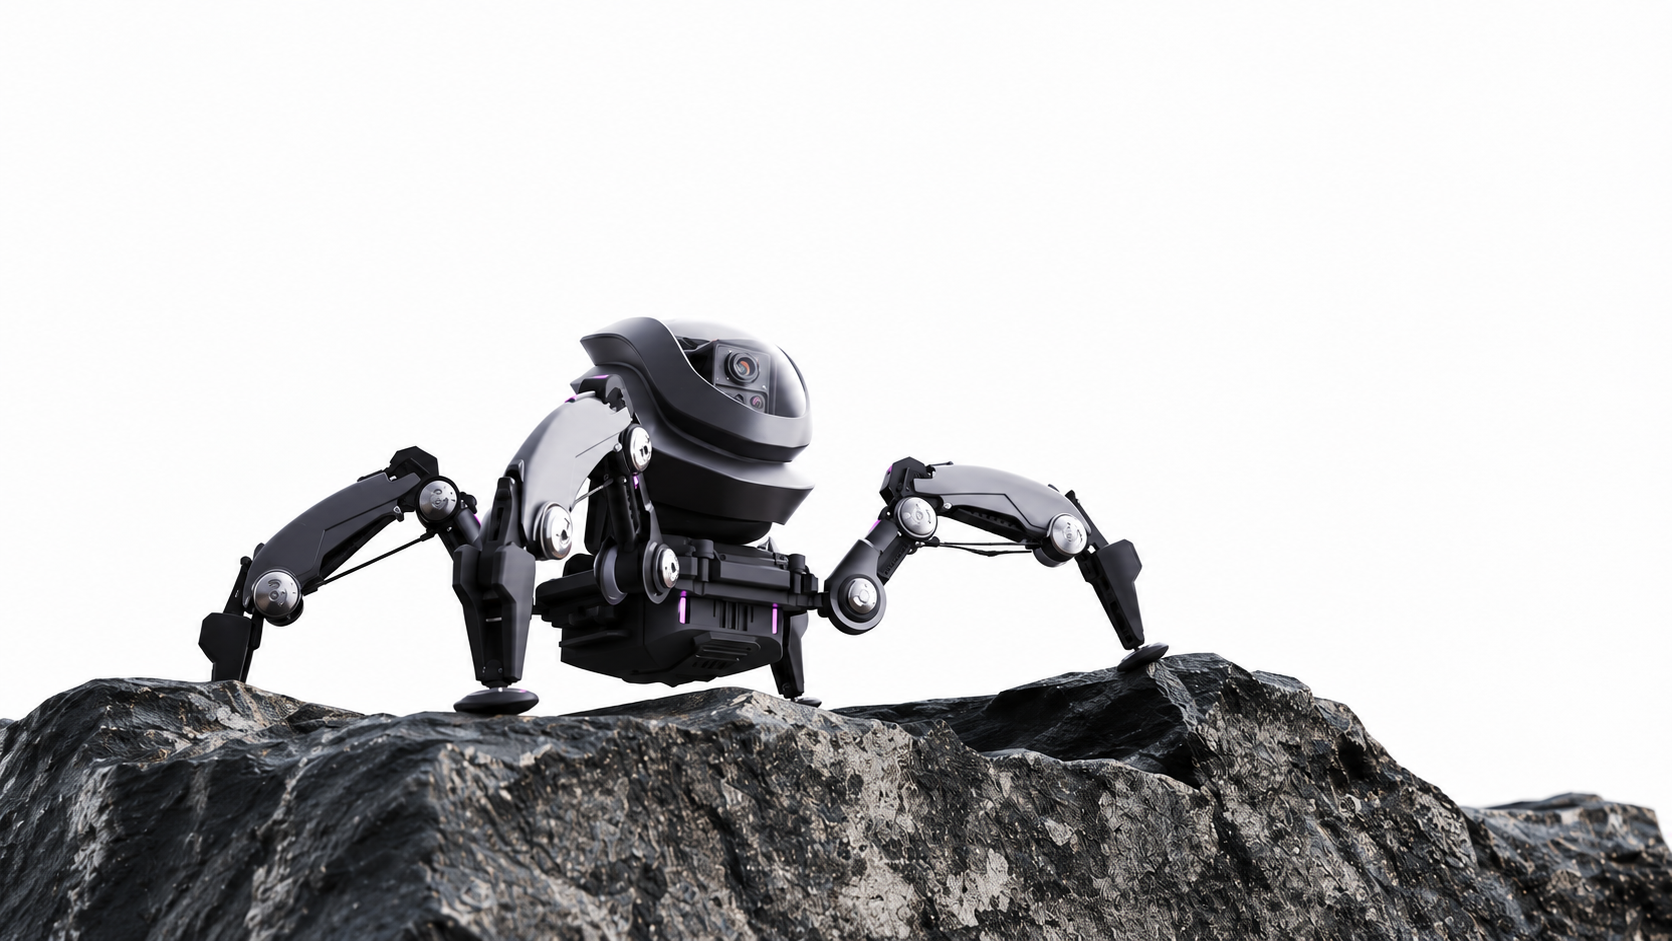
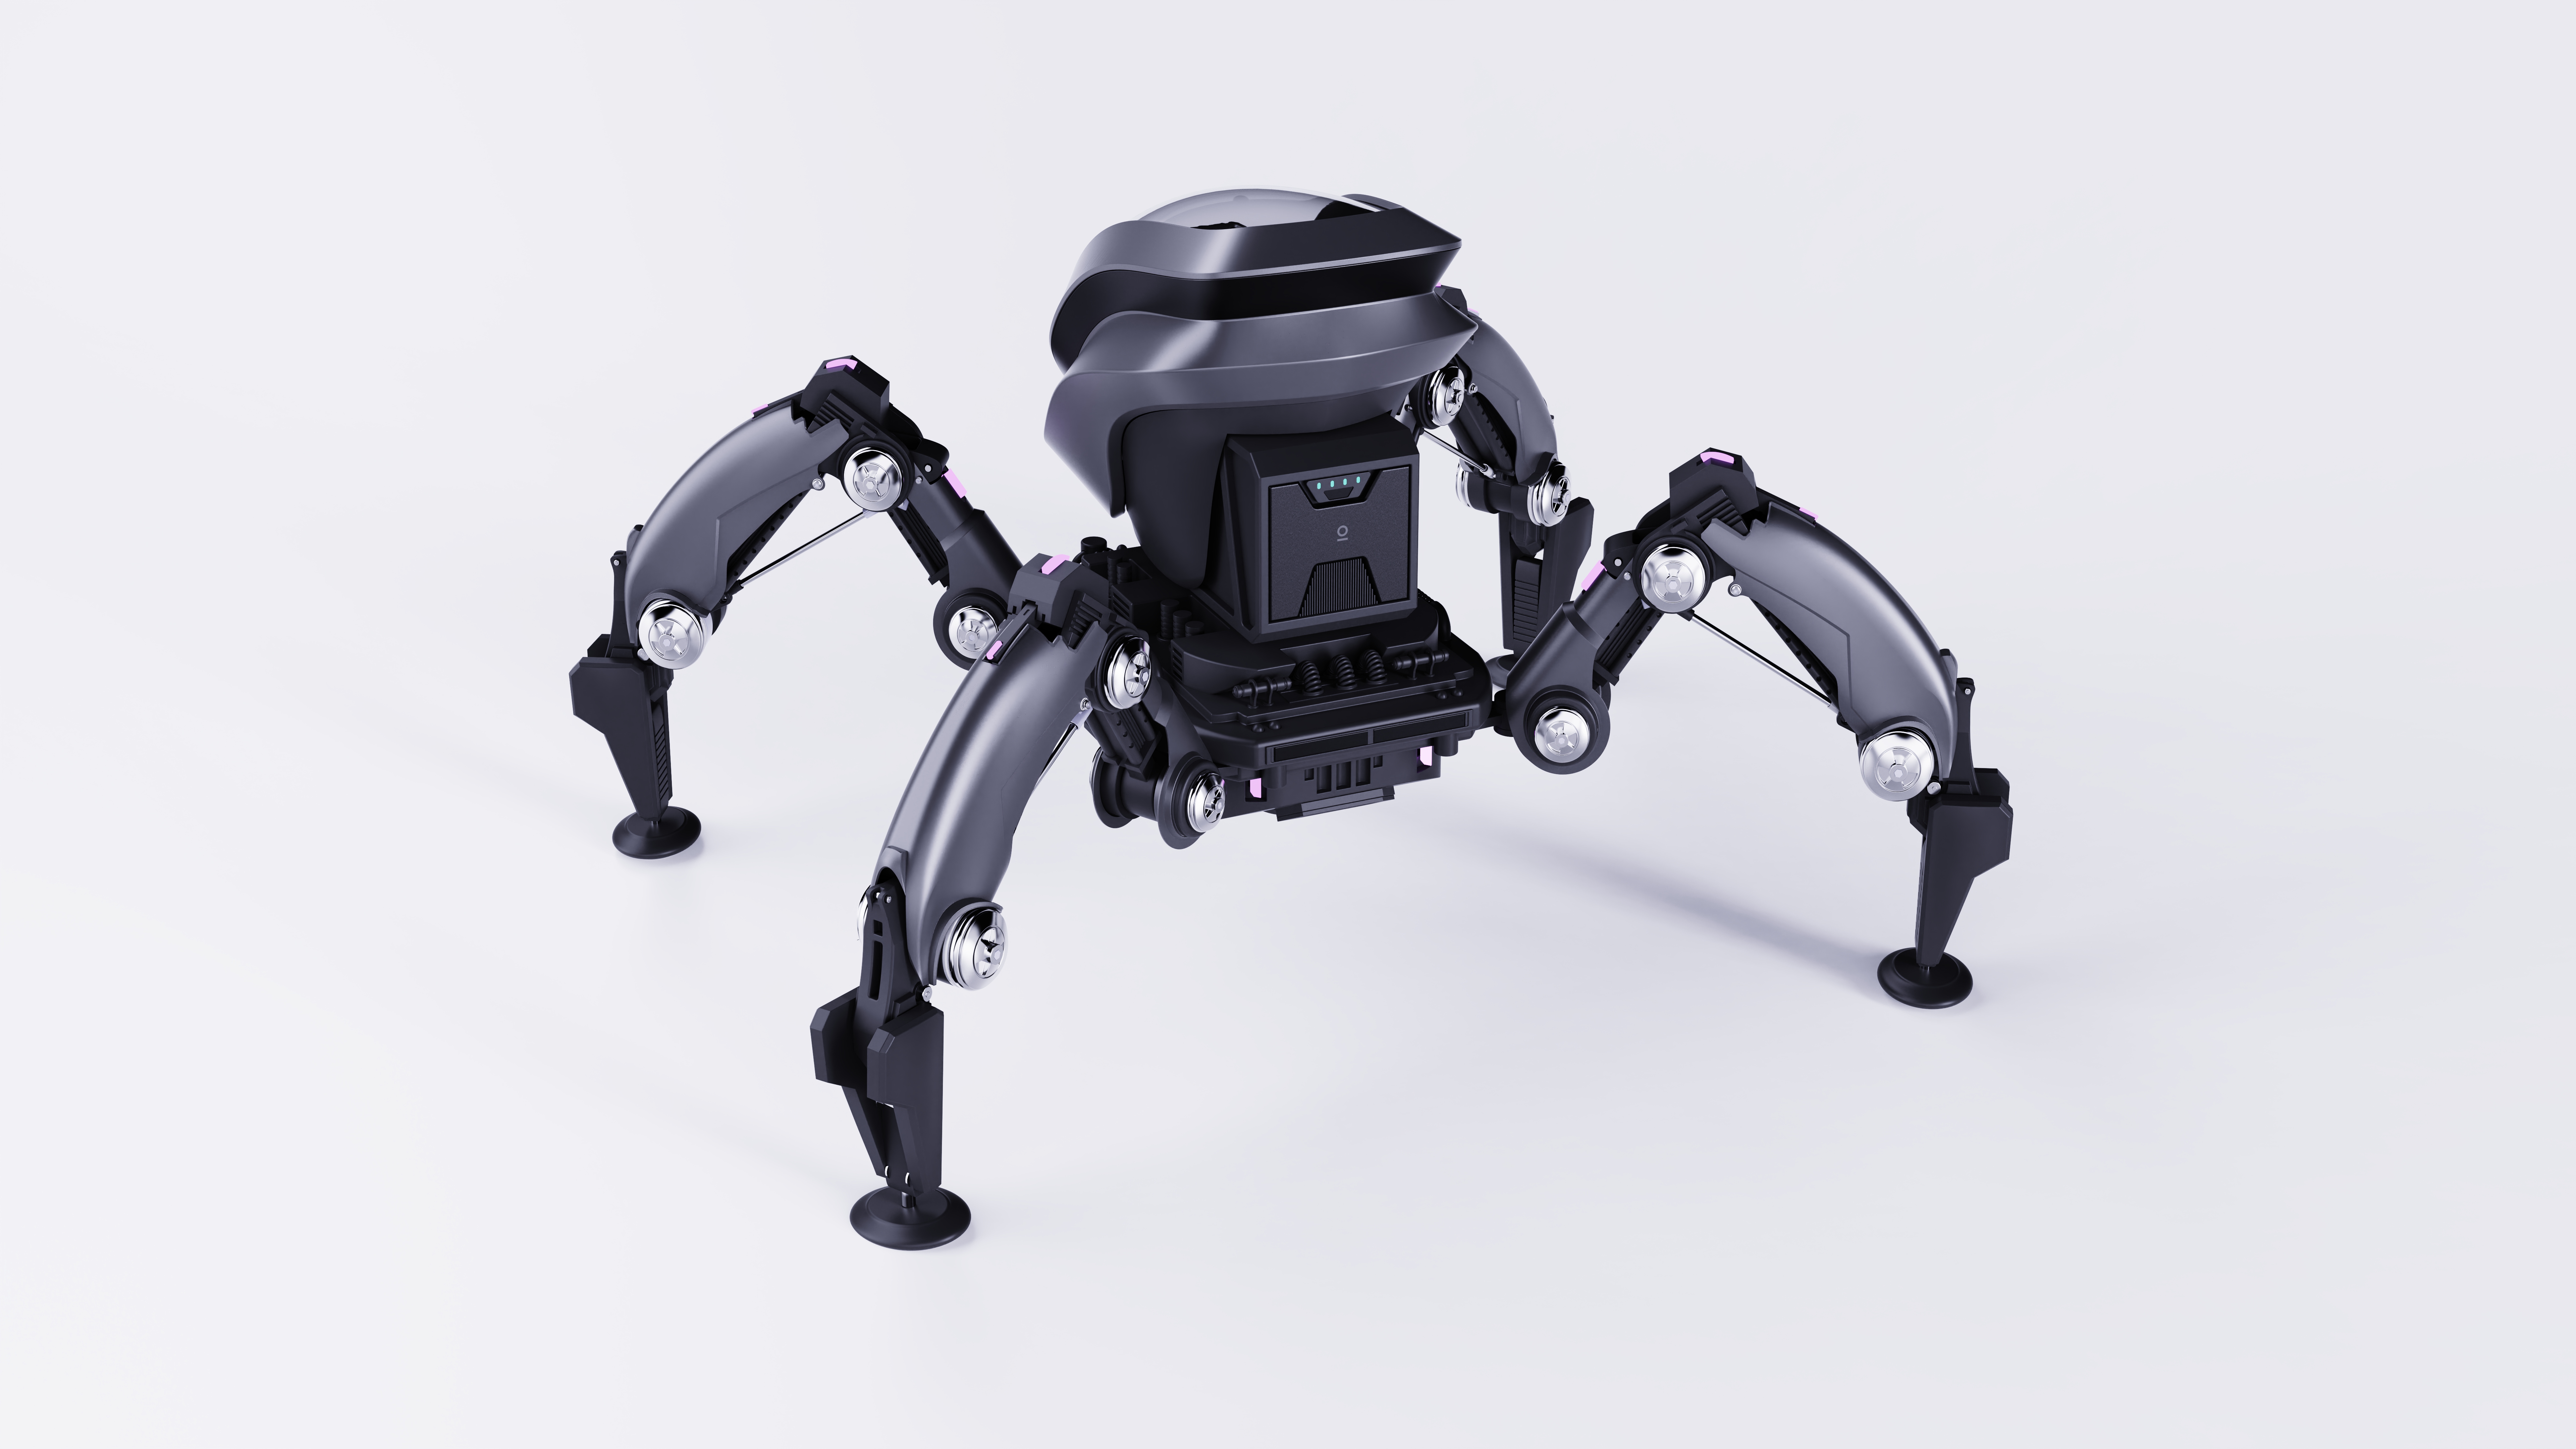
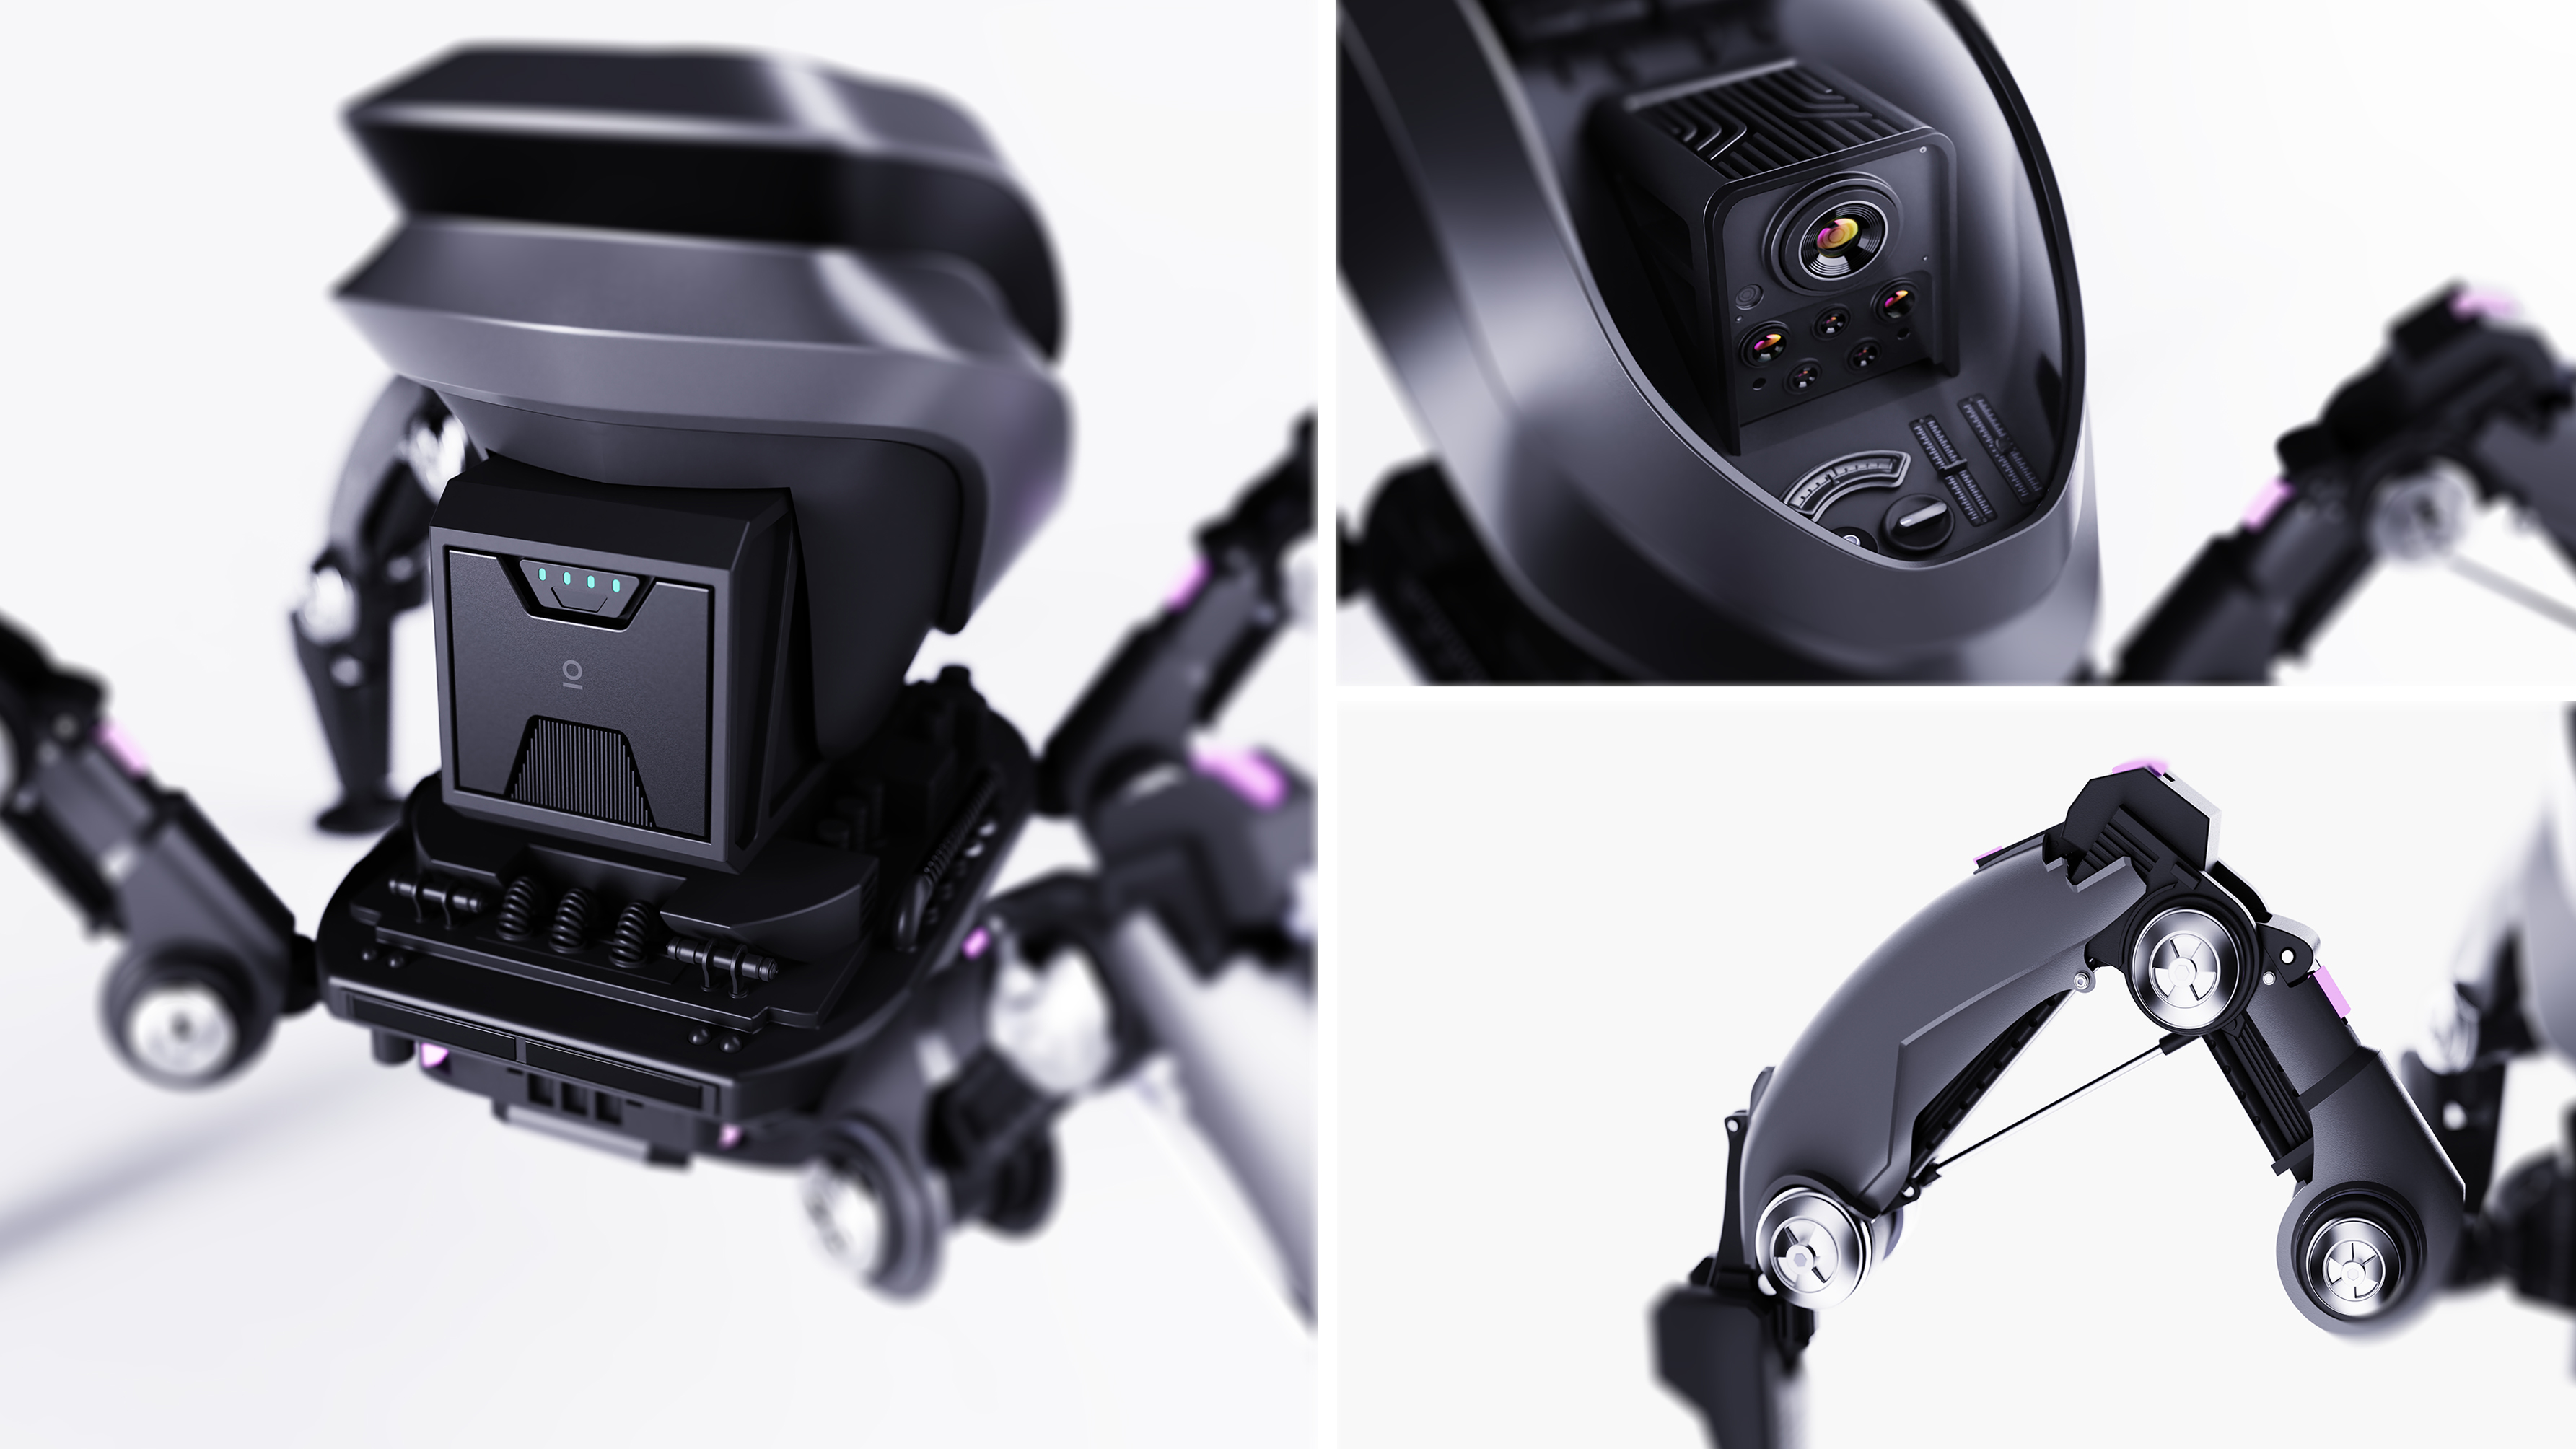
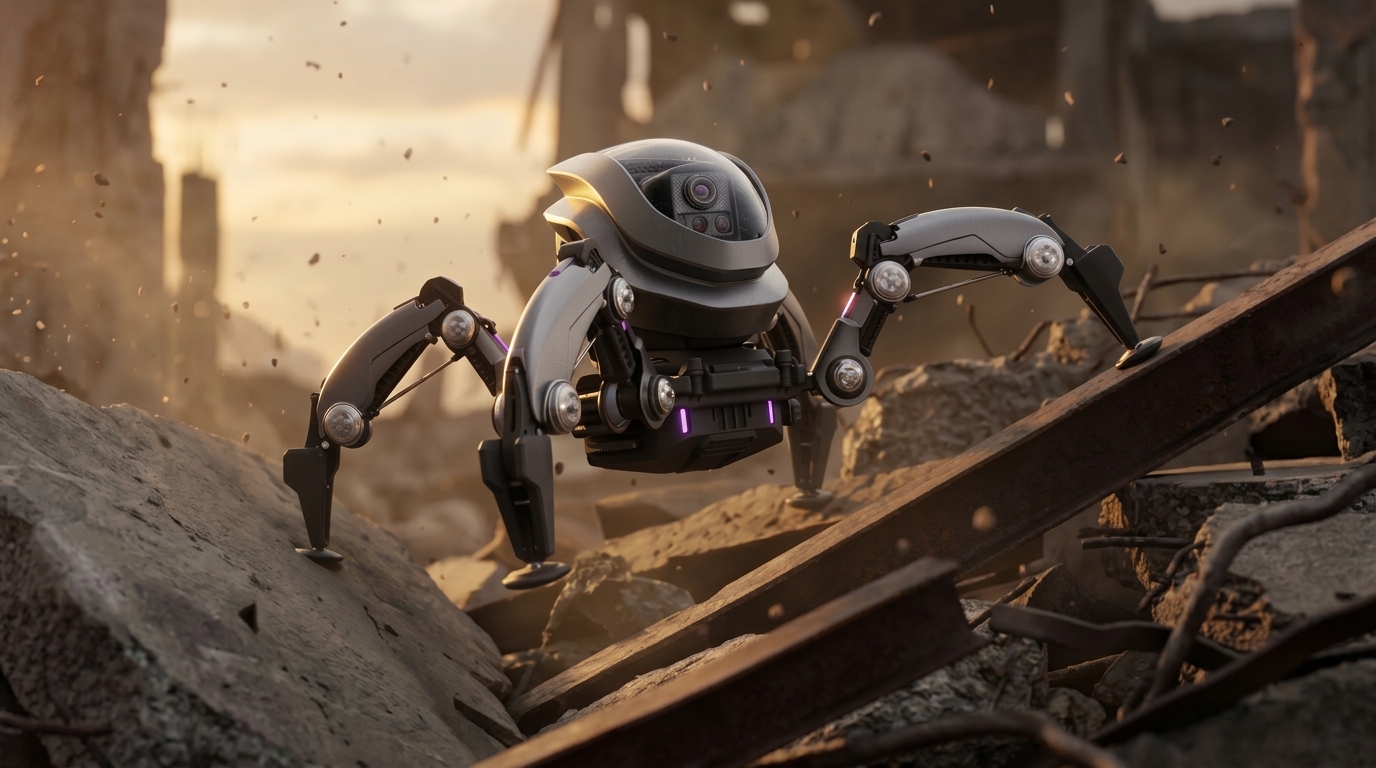
For extreme natural environments, disaster sites, narrow spaces and dangerous industrial environments, traditional detection equipment has problems such as difficulty in entering, insufficient mobility and high risk of manual operation. Therefore, based on the spider's flexible multi-joint motion and the ability to adapt to complex terrain, a bionic detection robot with complex environment adaptation and autonomous detection ability is designed.
The copyright of this work belongs to 王行. No use is allowed without explicit permission from owner.
New user?Create an account
Log In Reset your password.
Account existed?Log In
Read and agree to the User Agreement Terms of Use.
Please enter your email to reset your password


Different from others
Cool styling